

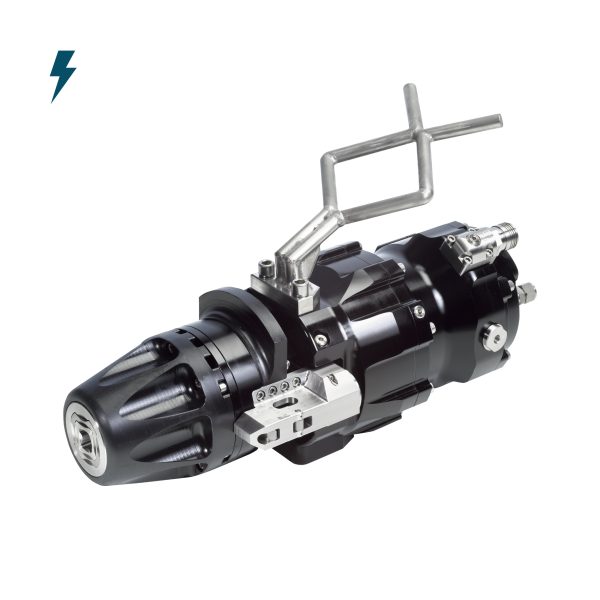
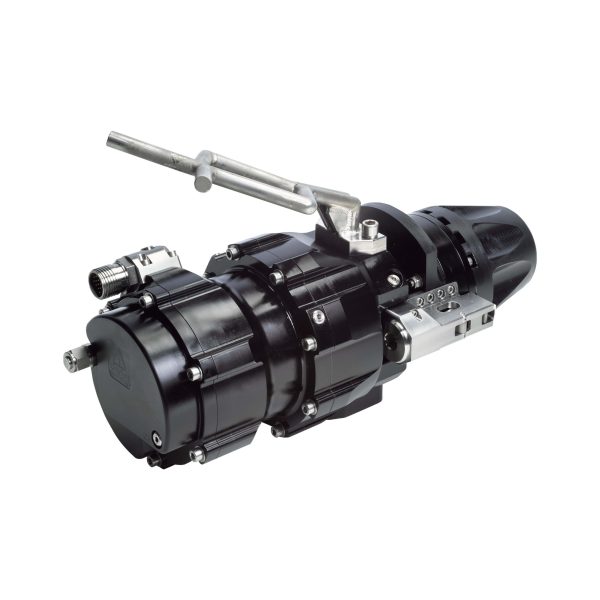
Class 1-4 (API 17D) Electric Torque Tool (ETT)
The Jupiter Electric Torque Tool (ETT) is designed for Class 1-4 Rotary Docking interfaces conforming to BS EN ISO 13628-8:2006 ROV interfaces on subsea production systems.
The Electric Torque Tool operates through a dedicated web browser interface, which enables seamless integration with both electric ROV’s and conventional ROV’s via an Intelligent Power Pod (IPP). The standard communication interface is Ethernet 10/100 Base-T.
- Working Torque: 30Nm to 2711Nm
- Max Working Speed: 6RPM (fully variable)
- Torque Control Accuracy: ±1% of Full Scale (271Nm to 2711Nm)
- ±10Nm (30Nm to 270Nm)
- Size: 580 x 227 x 215mm
- Lightweight
- Depth Rating: 3,000msw (options to 6,000msw)
- Power: 115VAC @ 1200W (other options available)
- Communication: Ethernet: 10/100 Base-T
- Serial: RS232 / RS485


